
gazebo

Install harmonic/stable of gazebo
Ubuntu 16.04 or later?
Make sure snap support is enabled in your Desktop store.
Details for gazebo
Package name
- gazebo
License
- Apache-2.0
Last updated
- 20 June 2025 - harmonic/stable
- 20 June 2025 - harmonic/candidate
Websites
Contact
External link warning
You are about to open
Do you wish to proceed?
Report a Snap Store violation
Report gazebo for a Snap Store violation
Snap Store Violation Report submitted successfully
Thank you for your report. Information you provided will help us investigate further.
Error submitting report
There was an error while sending your report. Please try again later.
Share this snap
Generate an embeddable card to be shared on external websites.
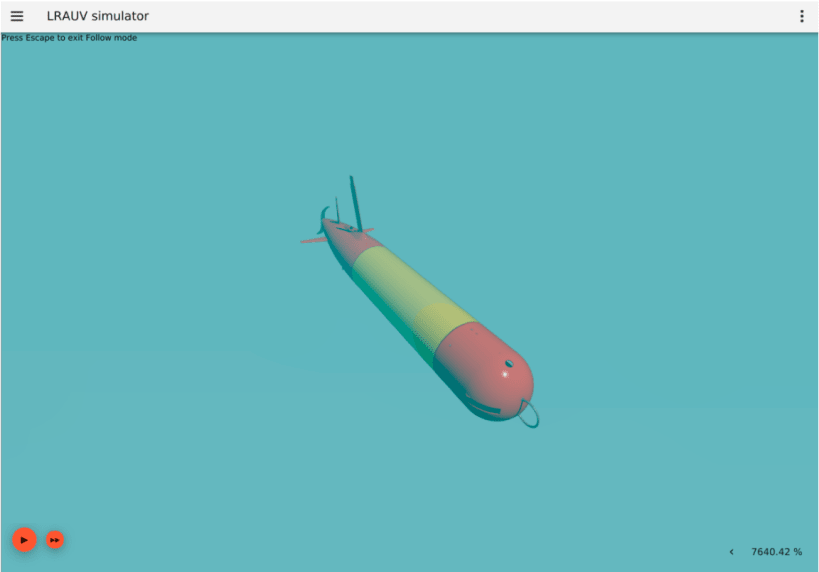
Iterate quickly on design concepts and control strategies with Ignition's rich suite of tools, libraries, and cloud services.
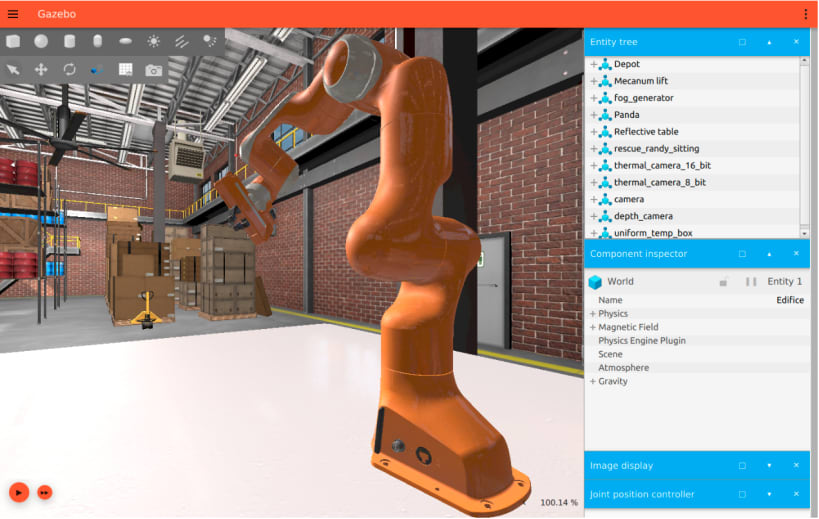
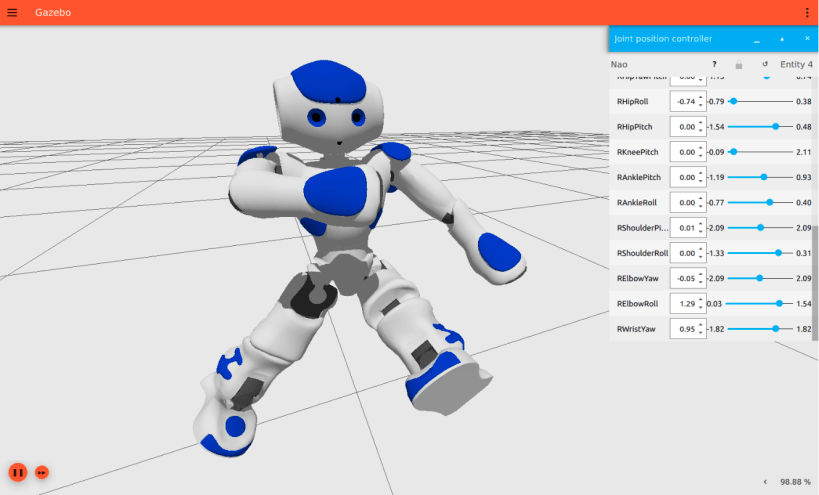
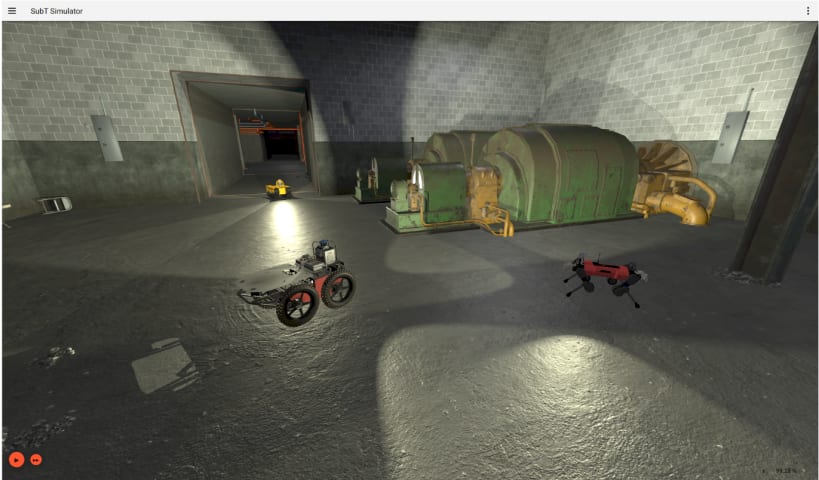
Gazebo (formerly known as Ignition [1]) is an open source robotics simulator maintained by Open Robotics [2].
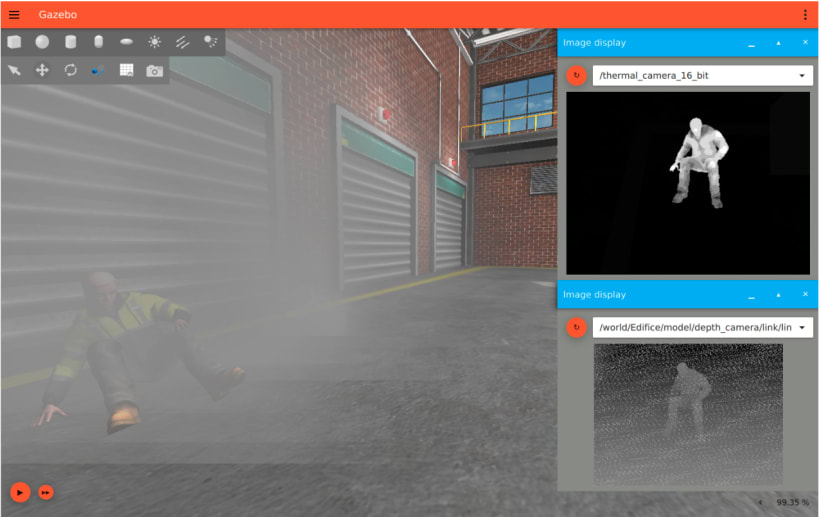
Through Gazebo, users have access to high fidelity physics, rendering, and sensor models. Additionally, users and developers have multiple points of entry to simulation, including a graphical user interface, plugins, and asynchronous message passing and services.
Gazebo brings a fresh approach to simulation with a complete toolbox of development libraries and cloud services to make simulation easy. Iterate fast on your new physical designs in realistic environments with high fidelity sensor streams. Test control strategies in safety, and take advantage of simulation in continuous integration tests.
Note: This is a beta release, do expect bugs and limitations. If you encounter any, please do report it [3].
Installation Instructions:
- Install Gazebo from a terminal,
snap install gazebo --edge
- Test your installation,
gazebo.gz gazebo shapes.sdf
If you are following the Gazebo 'Getting Started' documentation, you can replace the entire 'Step 1: Install' with the snap command and resume at 'Step 2: Run'.
Learn more about Gazebo on the official website [4].
[1] https://community.gazebosim.org/t/a-new-era-for-gazebo/1356
| Revision | Channel | Version | Build | Commit | Download SBOM |
|---|
The build and commit information is derived from build infrastructure records.
Install gazebo on your Linux distribution
Choose your Linux distribution to get detailed installation instructions. If yours is not shown, get more details on the installing snapd documentation.


